LiDArgus — Interactive LiDAR Control | ACM UIST 2025
BoRui (Scott) Li
Published
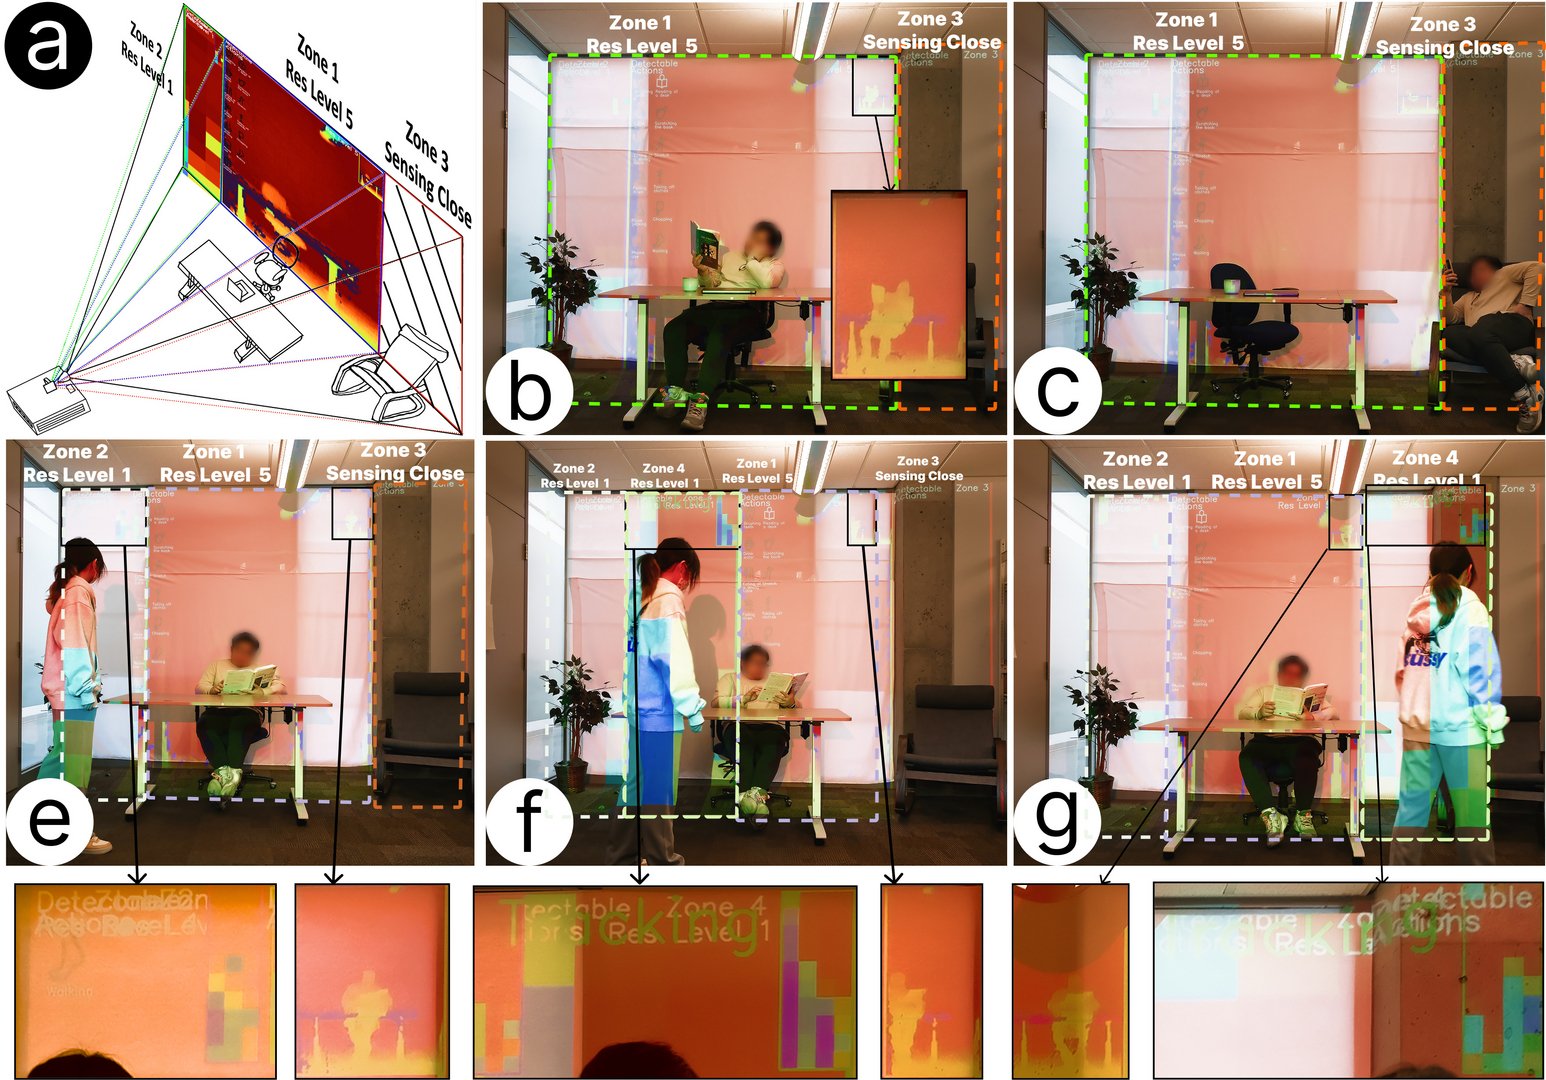
First-author research project published at ACM UIST 2025. LiDArgus combines speech input, object recognition and live point-cloud feedback to make LiDAR sensing easier to configure interactively.
The research prototype integrates a Lumotive M30 LiDAR and its SDK, TCP communication, Google Speech-to-Text, YOLO11 object detection and projected visual feedback. Users can define sensing zones, adjust resolution and disable selected regions through an interactive workflow.
This project demonstrates my technical work on interactive software, integrating hardware and software components, and connecting AI outputs to usable interfaces. Developed as a research collaboration, rather than a commissioned website.
Paper: https://www.twine.net/signin
The image is the teaser from our published paper.